Proceedings of the 1st International Symposium on Square Bamboos and the Geometree (ISSBG 2022)

Stability of Solutions in Mixed Differential Equations
Downloads:
3,260
Full-Text Views:
203
Citations (Scopus):
0
Citations (Crossref):
0
Cite This Article

1. DIFFERENCE AND DIFFERENTIAL EQUATIONS

1.1. Tumor Growth Cancer Model

In [1], the authors consider the following system where x′ describes the density of tumor cells, y′ the density of hunting predator cells and z′ the density of resulting cells:

x′=1+a1x1−x−k1xy−k2x      y′=a2yz−a3y−k3xy                          z′=a4z1−z−a5yz−a6z−k4xz(1)
  • •

    a1 is the growth rate of tumor cells

  • •

    a2 represents the conversion rate of the resulting cells to hunting predator cells

  • •

    a3 is the specific loss rate of hunting predator cells

  • •

    a4 represents the growth rate of resting cells

  • •

    a5 is the conversion rate of resting cells to hunting predator cells

  • •

    a6 is the specific loss rate of the resting cells

  • •

    k1 is the rate of killing of tumor cells by hunting cells

  • •

    k2 is the specific loss rate of tumor cells

  • •

    k3 represents the rate of killing of hunting predator cells by tumor cells

  • •

    k4 represents rate of killing of resting cells by tumor cells

The equilibrium points of the system shown in Eq. (1) are:

E00, 0, 0E1x1, 0, 0 where x1=121−k2a1+1−k2a12+4a1         a1>k2E2x2, 0,z2 where x2=121−k2a1+1−k2a12+4a1  and z2=1−a6a4−k4a4x2  a1>k2 and a4>a6+k4x2E3x3,y3,z3 where y3=1+a1x31−x3−k2x3k1x3 and z3=a3+k3x3a2     a1>k2

The equilibrium point E3x3,y3,z3 is globally asymptotically stable.

Example 1.

For the system shown in Eq. (1) with:
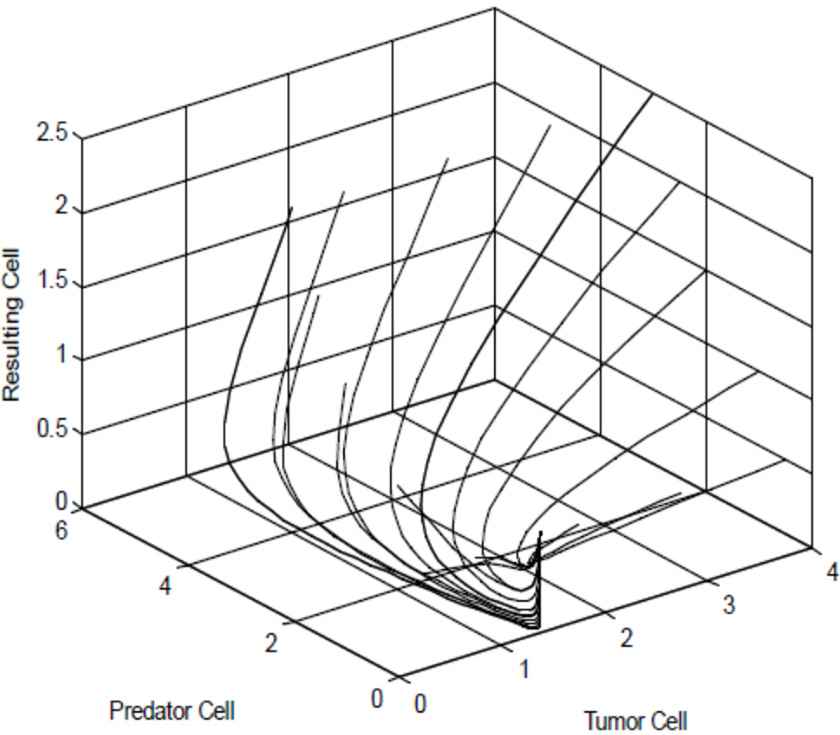
a1=0.6=a4,   a2=0.99,   a3=0.1,  a5=0.06,  a6=0.118k1=0.9,  k2=0.5,   k3=0.854,    k4=0.02
we obtain the equilibrium point E31.3213, 0.5656, 0.1186 globally asymptotically stable (Fig. 1).

Figure 1

The equilibrium point E3(1.3213, 0.5656, 0.1186).

1.2. Biolarvicides Against Malaria Model

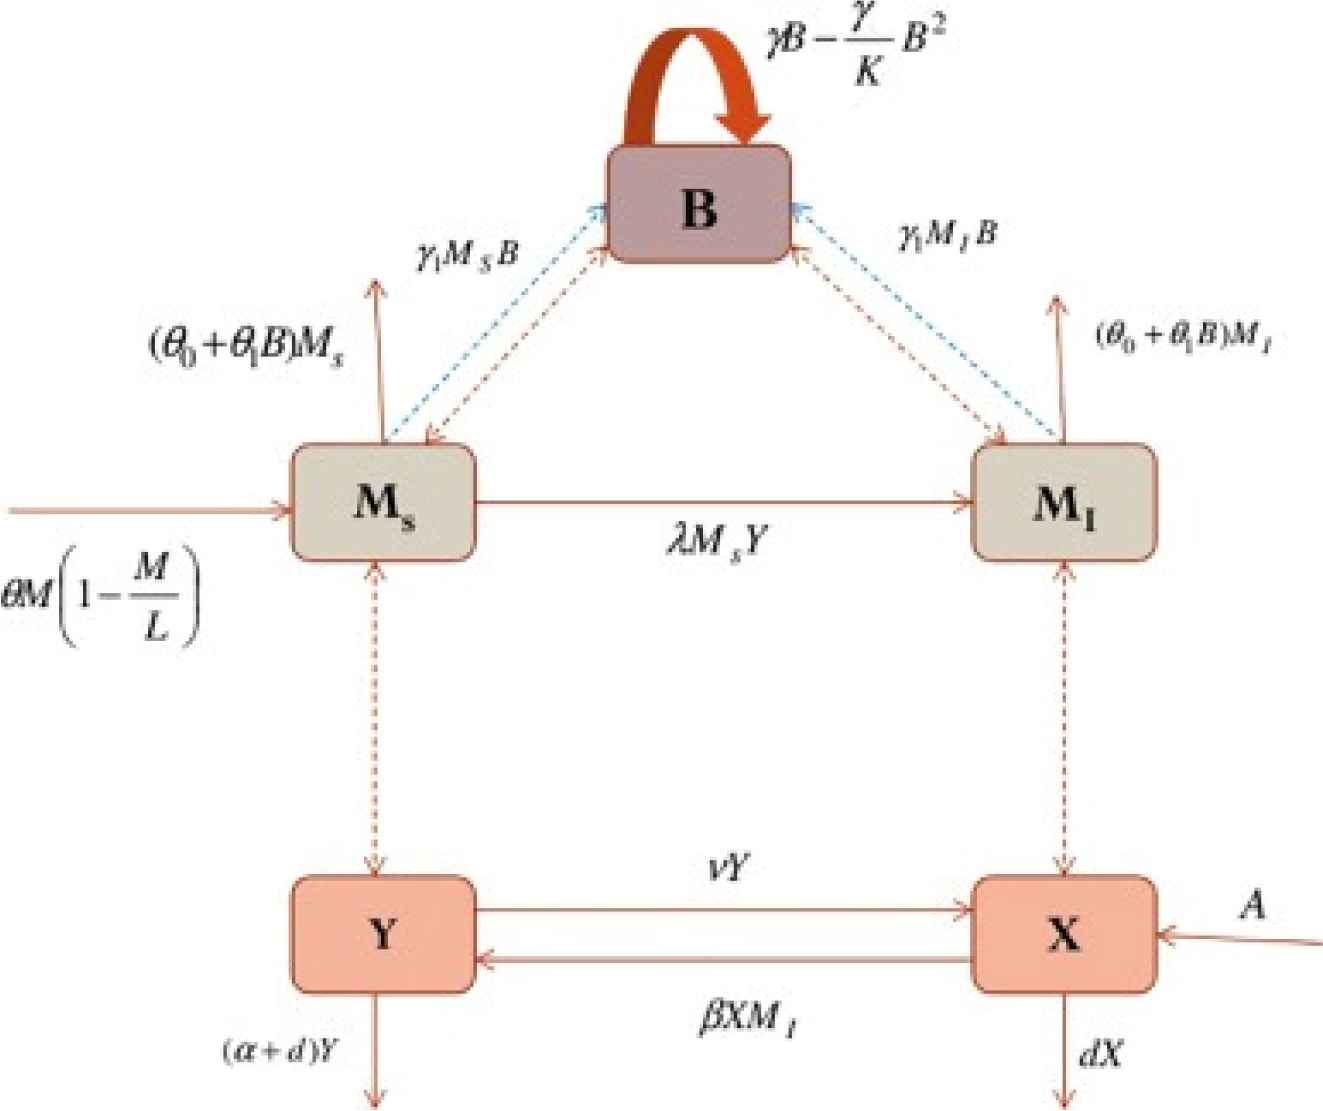
Biolarvicides are in use in several parts of the world for malaria vector control (see [2]). Consider the system:

x′=a−βxmI−dx+vyy′=βxmI−v−α−dymS'=θM1−mS+mIL−θ0+θ1BmS−λmsymI'=λmIy−θ0+θ1BmIB′=γB1−Bk+γ1mS+mIB(2)
  • •

    x represents the susceptible humans

  • •

    y represents the infected humans

  • •

    mS represents the susceptible mosquitoes

  • •

    mI represents the infected mosquitoes

  • •

    B represents the biolarvicide population (Fig. 2)

Figure 2

Schematic overview of the system. The direction of each solid line represents movement of population along that line within the same species. The bi-directional dotted lines between boxes indicate a mass-action interaction. The single directional dotted line indicates increase of bacteria population (for example, βxmI is a removal from x population and an addition to y population).

The equilibrium points of the system shown in Eq. (2) are:

  • •

    E0 ad, 0, 0, 0, 0 Disease free, unstable

  • •

    E1 ad, 0, 0, Lθ−θ0θ, 0 Disease free, unstable

  • •

    E2 ad, 0, 0, 0, K Disease free, unstable if θ−θ0θ1>k

  • •

    E3 x*,y*, mS*,mI*, 0 Endemic, unstable

  • •

    E4 ad, 0, mS*,0, B* Disease free, stable under conditions

  • •

    E5 x*,y*, mS*,mI*,B* Endemic, stable under conditions

2. DIFFERENCE AND DIFFERENTIAL EQUATIONS WITH DELAYS

2.1. Logistic Equations With Delays

Population density is unlikely to elicit an instant response to the per capita growth rate.

For example, the effect of food scarcity available to young immatures can only be felt later when they reach maturity expressing lower fertility rates. By designating τ the delay interval we get the delayed logistic equation:

N′t= rNt1−Nt−τK
or:
N′t= rNtK−Nt−τK+crNt−τ

The earliest delay model in mathematical biology is Hutchinson's equation in 1948 [3], when he modified the classical logistic equation, with a delay term to incorporate hatching and maturation periods into the model and account for oscillations, in the population of Daphnia. Such oscillations (Fig. 3) are in part due to the fact that the fertility of a parthenogenic female is determined, not merely by the population density at a given time, but also by the past densities to which it has been exposed [4].
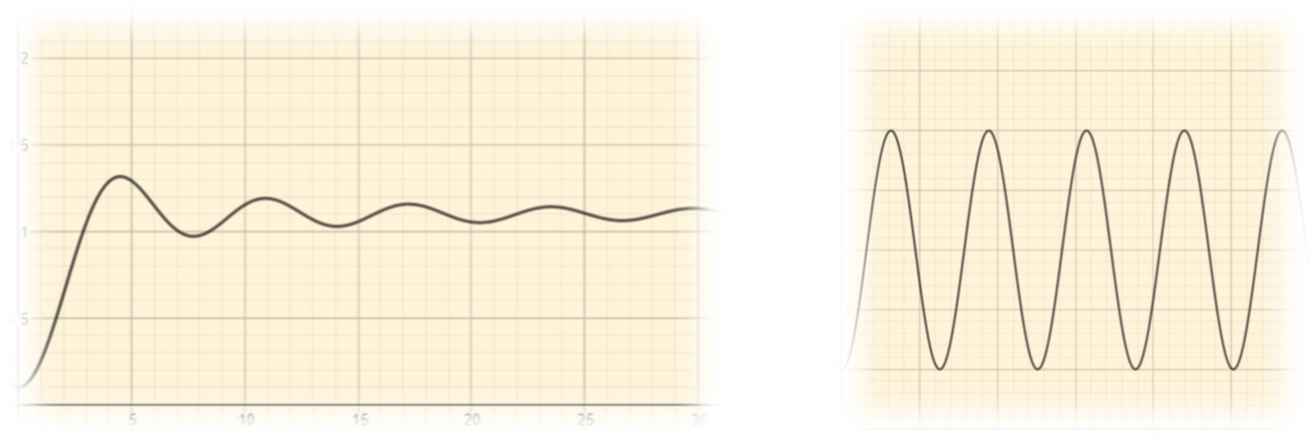
Figure 3

Oscillations.

2.2. Survival of Blood Cells

The delay differential equation:

N′t=−μNt+pe−γNt−τ
has been used by Wazewska-Czyzewska and Lasota [5] as a model for the survival of red blood cells (Fig. 4) in an animal. Here:
  • •

    μ is the probability of death of a red blood cell

  • •

    p and γ are positive constants and are related to the production of red blood cells per unit of time

  • •

    τ is the time required to produce a red blood cell

Figure 4

Red blood cells.

The delay differential equation:

N′t=−μNt+pe−γNt−τ
has a unique solution for each initial condition:
Nt=φt          −τ≤t≤0

The positive equilibrium point is given by:

N*=pμe−γN*

The solutions oscillate about N* if and only if the equation λ+μ+μγN*e−λτ=0 has no real roots.

2.3. Infinite Impulse Response Filter

A filter is a system that functions to extract the data from noise in a signal:
The defining equation for an IIR filter is the difference equation:

yn=∑i=1n1aiyn−i+∑i=0n2bixn−i
where:
  • •

    xn is the input signal

  • •

    yn is the output signal

  • •

    ai1≤i≤ni and bi0≤i≤n2 are real constants

In [6] it is shown that this equation is equivalent to the difference equation:

Δyn+∑l=0Lclyn−ρl+∑l=0n1+max1≤l≤L ρlpjyn−j=∑j=0n2+max1≤l≤L ρlqjxn−j

3. DIFFERENCE AND DIFFERENTIAL EQUATIONS WITH DELAYS AND ADVANCES

Mixed differential equations have mixed arguments, with delay and advance (Fig. 5). They occur in many problems in economy, biology, physics and engineering. However, this class of equations has been much less studied than other classes of functional differential equations.
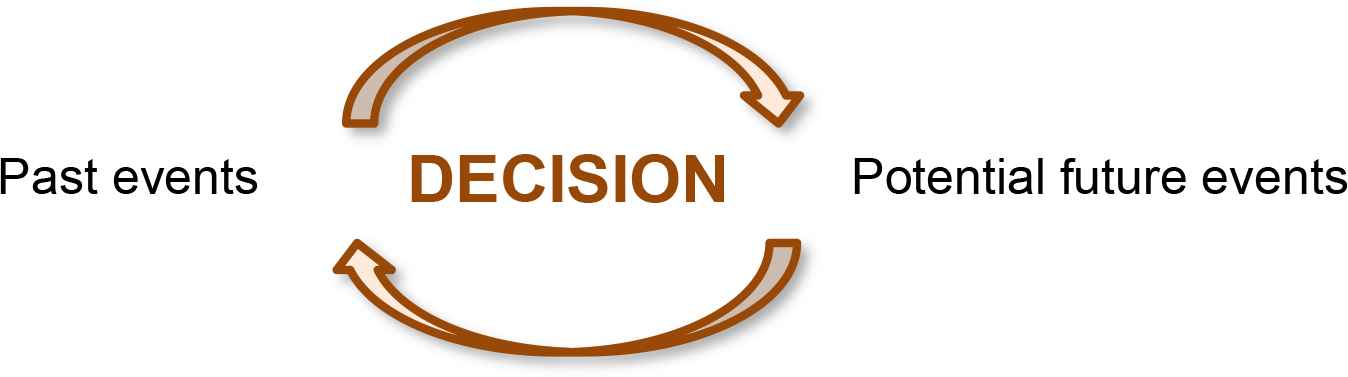
Figure 5

Mixed type equations allow to establish conditions between past and potential future events to get a good decision.

Why are these types of equations a challenge? It is well known that the solutions of these types of equations cannot be obtained in closed form [7]. It is not clear how to formulate an initial value problem for such equations and the existence and uniqueness of solutions becomes complicated [8]. To study the oscillation of solutions of differential equations, we need to assume that there exists a solution of such equations on the half line.

Example 2.

[9] Let the initial value problem with t0=0:

x′t−xht=0,  t≥0,      x0=0

With x′t advanced on 0, 2 and delayed on 2,∞ and with:

ht=1                         0≤t<1−t2+4t−2   1≤t<2 t−sint−2t≥2

Then:

xt=10≤t<112−t1≤t<2
is a solution of this initial value problem on 0, 2 which is unbounded on 0, 2 and cannot be extended to 2,∞.

Example 3.

[9] For α>0, the differential equation:

x′t+2αxt−α xt+1=0,  t≥0, x0= 1
has both infinitely growing and decaying solutions eλt on 0,∞, with λ positive and negative respectively. Indeed, for α=0.25:
xt=e-0.31812txt=e2.4773t

Remark:

Note that for the delayed argument ht≤t and 0≤α<1, any solution of the equation x′t+2αxt−α xht=0 tends to zero as t→+∞.

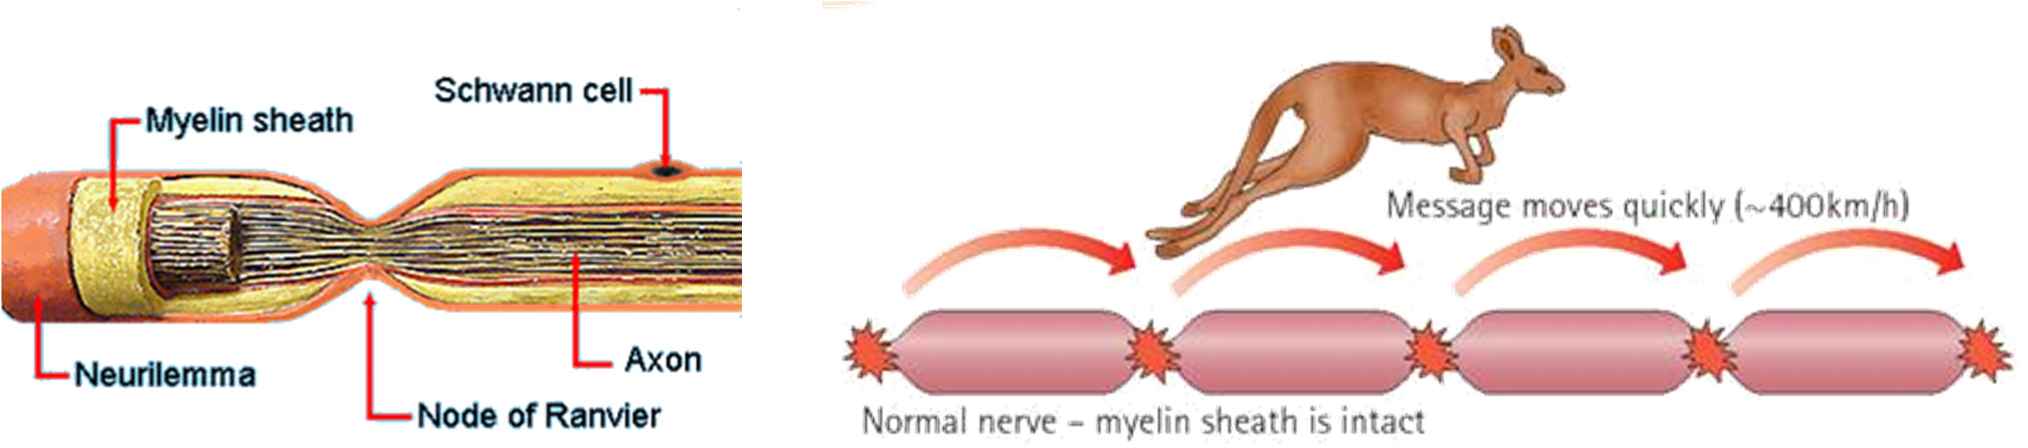
An example with nerve conduction was studied in [10].

The equation:
RC v′t = Fvt + v(t  vt+t
where t∈ℝ, v−∞=0 and v+∞=1, represents a model conduction in a myelinated nerve axon in which the myelin completely insulates the membrane, so that the potential change jumps from node to node (Fig. 6).

Figure 6

Nerve, consisting of axon, myelin sheath and nodes of Ranvier.

In the equation:

RCv′t=Fvt+vt +vt+t

vt represents the transmembrane potential at a node and the internodal delay τ represents the reciprocal of the speed of the potential wave as it propagates down the axon.

The constant r is unknown a priori and must be found simultaneously with vt. The constants R and C represent axoplasmic nodal resistivity and nodal capacity, respectively. F includes the model current-voltage relation.

Using the Ohm Law and the Taylor expansion around 0 the equation:

RCv′t=Fvt+vt +vt+t
will be transformed at:
v′t=a1vt+a2v2t+a3v3t+vt−τ−2vt+vt+t+Ov4

Using numerical methods, we obtain the solutions in Fig. 7.
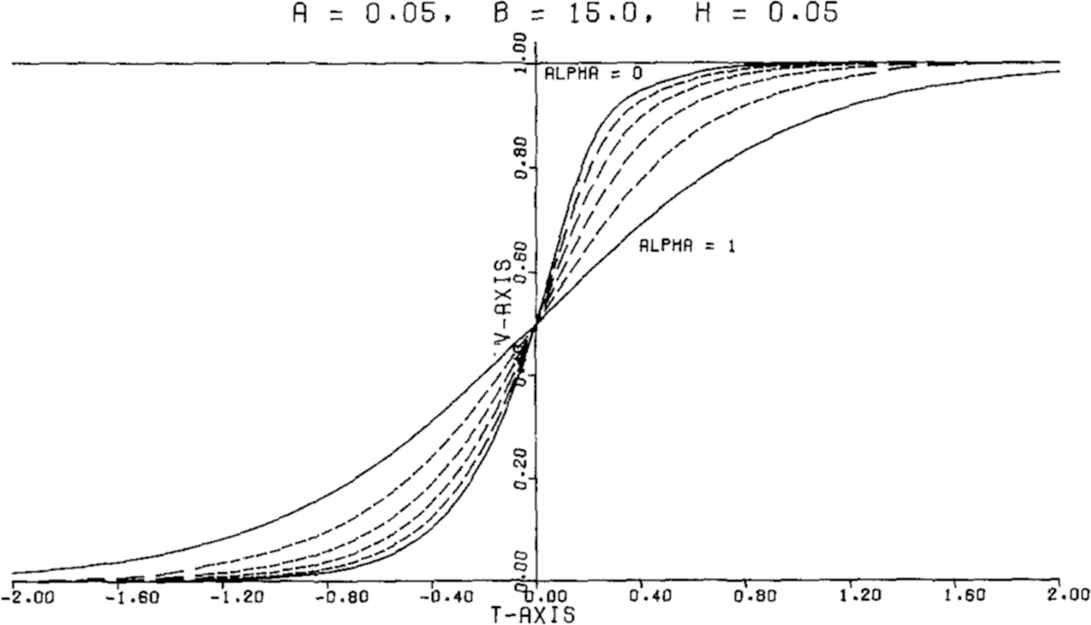
Figure 7

Graph of solutions changes when approaching target problem from test problem.

This means the rise time of the membrane potential is faster for lower threshold potential.

Example 4.

The linear autonomous mixed type differential equation:

x′t=∑i=1paixt−ri+∑j=1qbjxt+τj
where ai and bj are non-zero real numbers and ri and τj are positive real numbers, can arise in the study of traveling waves in regions with non-local interactions initiated in [11,12].

Example 5.

Stability and determinacy conditions for linear mixed type functional differential equations were studied in [13]:

x′t=∫−abxt+θdμθ
where μθ is a real-valued function of bounded variation on −a,b.

In this study, the necessary conditions for the existence, uniqueness and stability of a solution to mixed type functional equations were obtained.

4. STABILITY AND SOLUTIONS IN DIFFERENTIAL EQUATIONS WITH DELAYS AND ADVANCES

Consider the differential equation of mixed type:

x′t=∫−10xt−r1θdvθ+∫−10xt+r2θdηθ
where:
xt∈ℝ
  • •

    r1θ and r2θ are real non-negative continuous functions on −1,0

  • •

    vθ and ηθ are real-valued functions of bounded variation on −1,0

We define:

r1=maxr1θ:  −1≤θ≤0 r2=maxr2θ:  −1≤θ≤0

We specify an initial condition of the form:

xt=ϕt         −r1≤t≤r2
where the initial function ϕ is a given continuous real-valued function on the interval:
−r1, r2
satisfying the “consistency condition”:
ϕ′0=∫−10ϕ−r1θdvθ+∫−10ϕr2θdηθ

By a solution of:

x′t=∫−10xt−r1θdvθ+∫−10xt+r2θdηθ
we mean a continuous function x :−r1 , +∞→ℝ, which is differentiable on 0 , +∞ and satisfies the equation for every t≥0 .

If a solution of:

x′t=∫−10xt−r1θdvθ+∫−10xt+r2θdηθ
is searched in the form xt=eλt for t∈ℝ, the characteristic equation will be:
λ=∫−10e−λr1θdvθ+∫−10eλr2θdηθ

The solution of:

x′t=∫−10xt−r1θdvθ+∫−10xt+r2θdηθ
is said to be stable if for every ε>0 there exists a number ℓ=ℓε>0 such that, for any initial function ϕ with ϕ=max−r1≤t≤r2ϕt<ℓ , the solution satisfies xt<ε  for all t∈−‖r1‖ ,∞.

Otherwise, the solution is said to be unstable.

The solution is called asymptotically stable if it is stable in the above sense and in addition there exists a number ℓ0>0 such that, for any initial function ϕ with ‖ϕ‖<ℓ0 , the solution satisfies limt→∞xt=0.

5. ESTIMATION OF SOLUTIONS AND STABILITY CRITERIA

Theorem 1.

[14] Let λ0 be a real root of the characteristic equation and:

μλ0=∫−10r1θe−λ0r1θdVvθ+∫−10r2θeλ0r2θdVηθ<1βλ0=∫−10r1θe−λ0r1θdvθ−∫−10r2θeλ0r2θdηθ 

Then the solution x of:

x′t=∫−10xt−r1θdvθ+∫−10xt+r2θdηθ
satisfies:
xt≤1+μλ021+βλ0+μλ0Nλ0;ϕeλ0t
with:
Nλ0;ϕ=max−r1≤t≤r2e−λ0tϕt

Moreover, the solution is:

  • •

    stable if λ0=0

  • •

    asymptotically stable if λ0<0

  • •

    unstable if λ0>0

An important Lemma is the following.

Lemma 1.

[14] Assume that:

∫−10er1θrdvθ+∫−10e− r2θrdηθ>−1r  ;        ∫−10e− r1θrdvθ+∫−10er2θrdηθ<1r 
and:
∫−10r1θer1θrdVvθ+∫−10r2θe r2θrdVηθ≤1 
where r=maxr1,r2.

Then, in the interval −1r, 1r the characteristic equation:

λ=∫−10e−λr1θdvθ+∫−10eλr2θdηθ
has a unique root λ0 and this root satisfies the property:
μλ0=∫−10r1θe−λ0r1θdVvθ+∫−10r2θeλ0r2θdVηθ<1

Corollary 1.

[14] Assume that:

∫−10er1θrdvθ+∫−10e− r2θrdηθ>−1r   ,          ∫−10e− r1θrdvθ+∫−10er2θrdηθ<1r 
and:
∫−10r1θer1θrdVvθ+∫−10r2θe r2θrdVηθ≤1 
where r=maxr1, r2.

Then the solution of:

x′t=∫−10xt−r1θdvθ+∫−10xt+r2θdηθ 
is:
  • •

    asymptotically stable if v−1+η−1>v0+η0

  • •

    unstable if v−1+η−1<v0+η0

Example 6.

[14] Consider the equation:

x′t=∫−10xt−θ+12dθ+124+∫−10xt+−θ4dη−32θ

Notice that in this case we have:

r1θ=θ+12;     vθ=θ+124;    r2θ=−θ4;    ηθ=−32θ

The characteristic equation is:

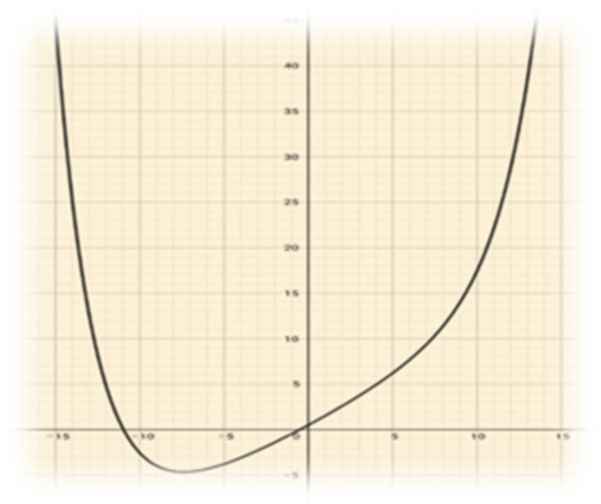
λ=∫−10e−λθ+12dθ+124+∫−10eλ−θ4d−32θ     =12∫−10e−λθ+12θ+1−3e− λθ4dθ=1λ 2λ1−e− λ2−e− λ2− 6e λ4−1

So, F2λ=λ−1λ 2λ1−e− λ2−e− λ2− 6e λ4−1 (Fig. 8).

Figure 8

The function F2λ=λ−1λ 2λ1−e− λ2−e− λ2− 6e λ4−1.

The only one root of F2 is λ≅−0.98.

Then, for λ0=−0.98 the condition of Theorem 1 is satisfied. In fact, since v is increasing on −1,0 and  η is decreasing on −1,0:

μλ0=μ−0.98≤max−1≤θ≤0e0.98θ+12θ+12Vθ+124−1,0+max−1≤θ≤0e0.98θ4−θ4V−32θ−1,0=e0.9822⋅14+e− 0.9844⋅32≅0.5<1

So, the solution is asymptotically stable.

In this example, stability analysis can be performed using Corollary 1 of Lemma 1 without using the characteristic equation. Indeed, we get:

∫−10eθ+1dθ+124+∫−10eθ2d−32θ =12∫−10θ+1eθ+1−3eθ2dθ≅−0.68>−2∫−10e−θ+1dθ+124+∫−10e−θ2d−32θ =12∫−10θ+1e−θ+1−3e− θ2dθ≅−1.68<2∫−10θ+12eθ+1dVθ+124+∫−10−θ4e− θ2dV−32θ ≤e2⋅14+e4⋅32≅0.96≤1

Thus, according to Lemma 1, it states that a real root must pass in the interval (−2, 2).

Finally, from Corollary 1 we obtain:

v−1+η−1=0+32>v0+η0=14+0
and thus the solution is asymptotically stable.

Example 7.

Consider the equation:

x′t=∫−10xt−−θ2d−θ4+∫−10xt+−θ2dη−θ4

Here r1θ=−θ2, vθ=−θ4, r2θ=−θ2, ηθ=−θ4 and the characteristic equation is given by:

λ=∫−10e−λ−θ2d−θ4+ ∫−10eλ−θ2d−θ4     =−14∫−10eλθ2+e− λθ2dθ     =−12λeλ2−e− λ2

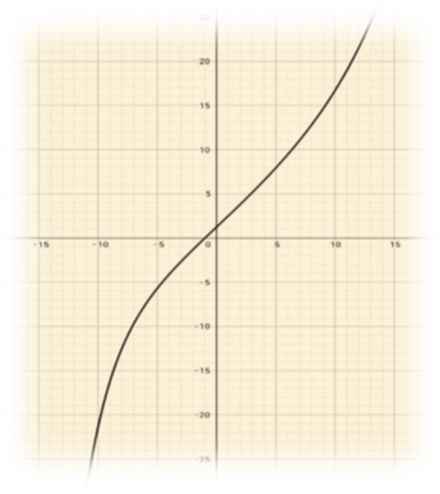
So, F3λ=λ+12λeλ2−e− λ2.

The graph of the function F3 (Fig. 9) shows that F3 has two roots: λ≅−0.5 and λ≅−11.

Figure 9

The function F3λ=λ+12λeλ2−e− λ2.

Let λ=−11:

β−11=∫−10−θ2e− 11θ2d−θ4−∫−10−θ2e 11θ2d−θ4≅2.46≤μ−11

So for λ0=−11 Theorem 1 cannot be applied.

Let λ=−0.5:

μλ0=μ−12=∫−10−θ2e− θ4dV−θ4+∫−10−θ2e θ4dV−θ4 ≤ e142⋅14+e− 142⋅14≅0.26<1

Then for λ0=−0.5 the conditions of Theorem 1 are satisfied. So the solution is asymptotically stable.

ACKNOWLEDGMENT

Supported by the Center for Research and Development in Mathematics and Applications (CIDMA) through the Portuguese Foundation for Science and Technology (FCT – Fundação Para a Ciência e a Tecnologia), references UIDB/04106/2020 and UIDP/04106/2020.

REFERENCES

K. Das, M.N. Srinivas, N.H. Gazi, S. Pinelas. Stability of the Zero Solution of Nonlinear Tumor Growth Cancer Model Under the Influence of White Noise. International Journal of Systems Applications, Engineering & Development, 2018, 12: 12–27.
S. Pandey, S. Nanda, A. Vutha, R. Naresh. Modeling the Impact of Biolarvicides on Malaria Transmission. Journal of Theoretical Biology, 2018, 454: 396–409. https://doi.org/10.1016/j.jtbi.2018.06.001
G.E. Hutchinson. Circular Causal Systems in Ecology. Annals of the New York Academy of Sciences, 1948, 50(4): 221–246. https://doi.org/10.1111/j.1749-6632.1948.tb39854.x
I. Györi, G. Ladas. Oscillation Theory of Delay Differential Equations: With Applications. Oxford: Clarendon Press, 1992.
M. Wazewska-Czyzewska, A. Lasota. Mathematical Models of the Red Blood Cell System. Matematyka Stosowana, 1976, 6: 25–40.
G.E. Chatzarakis, G.N. Miliaras. Asymptotic Behavior in Neutral Difference Equations With Several Retarded Arguments. Rocky Mountain Journal of Mathematics, 2015, 45(1): 131–156. https://doi.org/10.1216/RMJ-2015-45-1-131
S. Pinelas. Asymptotic Behavior of Solutions to Mixed Type Differential Equations. Electronic Journal of Differential Equations, 2014, 210: 1–9.
A.F. Yeniçeriođlu, C. Yazýcý, S. Pinelas. On the Stability and Behavior of Solutions in Mixed Differential Equations With Delays and Advances. Mathematical Methods in the Applied Sciences, 2022, 45(8): 4468–4496. https://doi.org/10.1002/mma.8049
L. Berezansky, E. Braverman, S. Pinelas. Exponentially Decaying Solutions for Models With Delayed and Advanced Arguments: Nonlinear Effects in Linear Differential Equations. Proceedings of the American Mathematical Society, 2023, 151(10): 4261–4277. https://doi.org/10.1090/proc/16383
H. Chi, J. Bell, B. Hassard. Numerical Solution of a Nonlinear Advance-Delay-Differential Equation From Nerve Conduction Theory. Journal of Mathematical Biology, 1986, 24(5): 583–601. https://doi.org/10.1007/BF00275686
J. Mallet-Paret. The Fredholm Alternative for Functional Differential Equations of Mixed Type. Journal of Dynamics and Differential Equations, 1999, 11(1): 1–47. https://doi.org/10.1023/A:1021889401235
J. Mallet-Paret. The Global Structure of Traveling Waves in Spatially Discrete Dynamical Systems. Journal of Dynamics and Differential Equations, 1999, 11(1): 49–127. https://doi.org/10.1023/A:1021841618074
H. d’Albis, E. Augeraud-Véron, H.J. Hupkes. Stability and Determinacy Conditions for Mixed-Type Functional Differential Equations. Journal of Mathematical Economics, 2014, 53: 119–129. https://doi.org/10.1016/j.jmateco.2014.06.008
A.F. Yeniçeriođlu, S. Pinelas, Y. Yan. On the Behavior of the Solutions for Linear Autonomous Mixed Type Difference Equation. Rendiconti del Circolo Matematico di Palermo: Series 2, 2020, 69(3): 787–801. https://doi.org/10.1007/s12215-019-00435-y

Cite This Article

ris
TY  - CONF
AU  - Sandra Pinelas
PY  - 2023
DA  - 2023/11/29
TI  - Stability of Solutions in Mixed Differential Equations
BT  - Proceedings of the 1st International Symposium on Square Bamboos and the Geometree (ISSBG 2022)
PB  - Athena Publishing
SP  - 71
EP  - 83
SN  - 2949-9429
UR  - https://doi.org/10.55060/s.atmps.231115.007
DO  - https://doi.org/10.55060/s.atmps.231115.007
ID  - Pinelas2023
ER  -
enw
bib